ES · EN
Contact us
Autonomous driving integrated into the vehicle: our own perception, localisation, navigation and safety, with camera and LiDAR fusion, on different types of vehicle.
Design of the sensor configuration on the real 3D CAD.
Validation of the configuration before assembly.
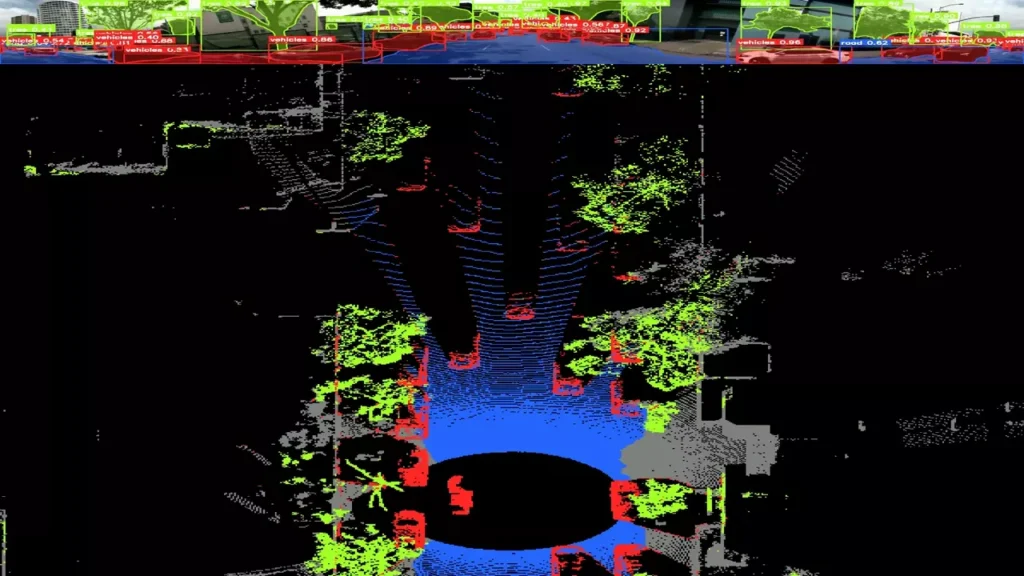
2D/3D detection and classification and multi-object tracking.
Precise positioning and planning to drive autonomously.
Autonomous vehicle running routes in closed traffic. Providing the system with obstacle perception and its own localisation.
Licensed integration of Seevia's perception and localisation stack
2D detection of frontal objects, 3D detection and tracking, and LiDAR + GNSS localisation.
3 cameras
4 LiDAR
1 GNSS + IMU
Configuration designed on the vehicle's real 3D CAD, with calibration and synchronisation.
In-house, sensor-agnostic perception based on camera and LiDAR fusion.
LiDAR + GNSS/IMU and automated HD map generation.
Safety functions (ASIL-B) and supervision on automotive ECUs.
Stack
Perception, localisation, navigation and safety.
Perception
2D/3D detection, multi-object tracking, camera + LiDAR fusion.
Maps
Automated generation of HD maps.
Design
Custom design of on-board sensors using the real 3D CAD, calibration and synchronisation.
Sensor-agnostic
The sensor set can change without rebuilding the perception layer.
Compatible
Suitable for multiple mobile platforms: L7e, shuttles, cars and buses.
Functions
Development of safety functions (ASIL-B) and supervision on automotive ECUs.
Options
Licensed integration, engineering projects, pilots and proofs of concept.