ES · EN
Contact us
Position without satellites
Between tall buildings or under cover, GPS dies. We record with LiDAR, camera and IMU; generate HD maps for autonomous vehicles; the vehicle localises itself by matching live point clouds to that map in real time. It does not rely on satellites alone.
The vehicle locates itself on the orthophoto by fusing its LiDAR with the map. Orthophoto: PNOA courtesy of © Instituto Geográfico Nacional.
Localising means working out the vehicle's pose by comparing live LiDAR with a high-definition map. An HD map describes lanes, edges and drivable areas so the vehicle can decide on its own. We distinguish three: navigation, localisation and perception.
GNSS fails under roofs, between tall buildings or beside stacked containers, exactly where precision matters. Hand-made maps are slow, costly and go stale when the site changes.
Illustrative diagram
01
We drive through the area with the sensor-equipped vehicle.
02
We generate the map automatically from the drives and review it before use.
03
From the map we work out where the vehicle can drive.
04
With the map and the vehicle's sensors we calculate its position, even without satellite.
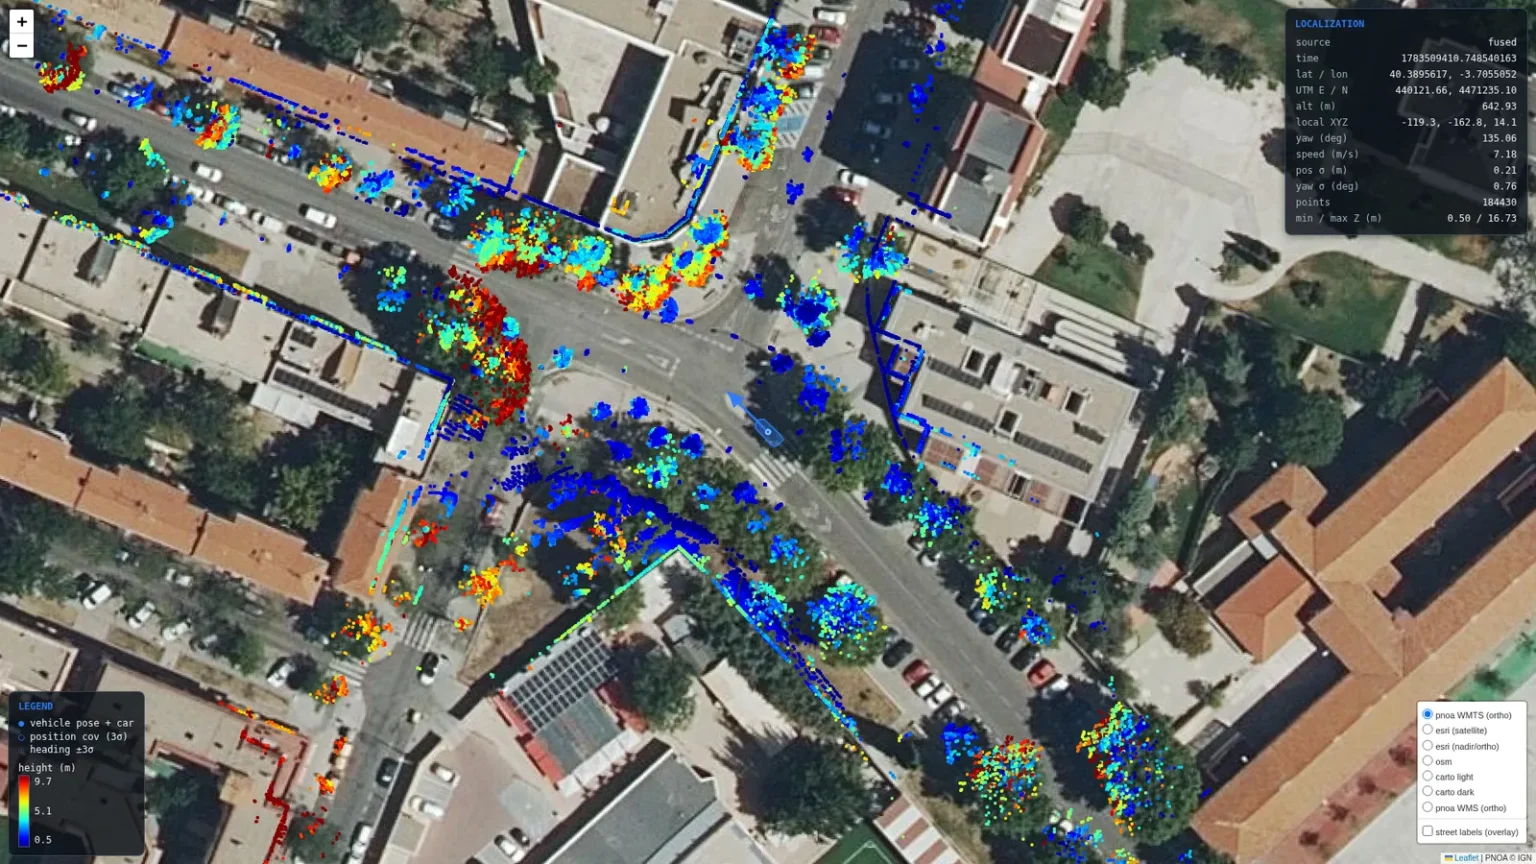
Localisation on georeferenced LiDAR.
A satnav describes streets for people; a high-definition map details lanes so that a vehicle can decide.
Each new pass is compared with the previous one and changes are updated.
Yes. If they are georeferenced, we make use of them.
Tell us your case and we will look at it with your data.
Next
Navigation and control