Seevia Drive
Autonomous driving integrated into your vehicle
Sensors, computing and our own perception, localisation and navigation software, integrated into each platform. We choose the sensor for each case and adapt the software to it.
Camera, bird's-eye view and 3D scene with detected objects.
Our own building block that brings together perception, localisation, navigation and digital twins. We integrate it into cars, shuttles, buses and light vehicles.
What it solves
Changing a sensor usually means rewriting the software, and hand-made maps go out of date. Seevia Drive fuses camera and LiDAR with our own perception and generates maps from the vehicle's drives.
Sensor-independent software
Perception adapts to the camera and LiDAR you choose, and a sensor change keeps the software.
Automatically generated maps
Maps are generated from the vehicle's drives and updated on every pass.
Simulation tests before the track
With calibrated sensors and a twin of the vehicle, the same software is tested in virtual environments before the track.
Illustrative diagram
10
vehicles with Seevia technology developed and integrated
73
modules developed and validated in real deployments
How it works
01
Camera detection
Vehicles, people and objects detected in the image.
Detection in the image: each object with its box.
02
3D classification with LiDAR
The point cloud around the vehicle, classified.
Classified LiDAR cloud around the vehicle.
03
Sensor fusion
Camera and LiDAR in the same reference.
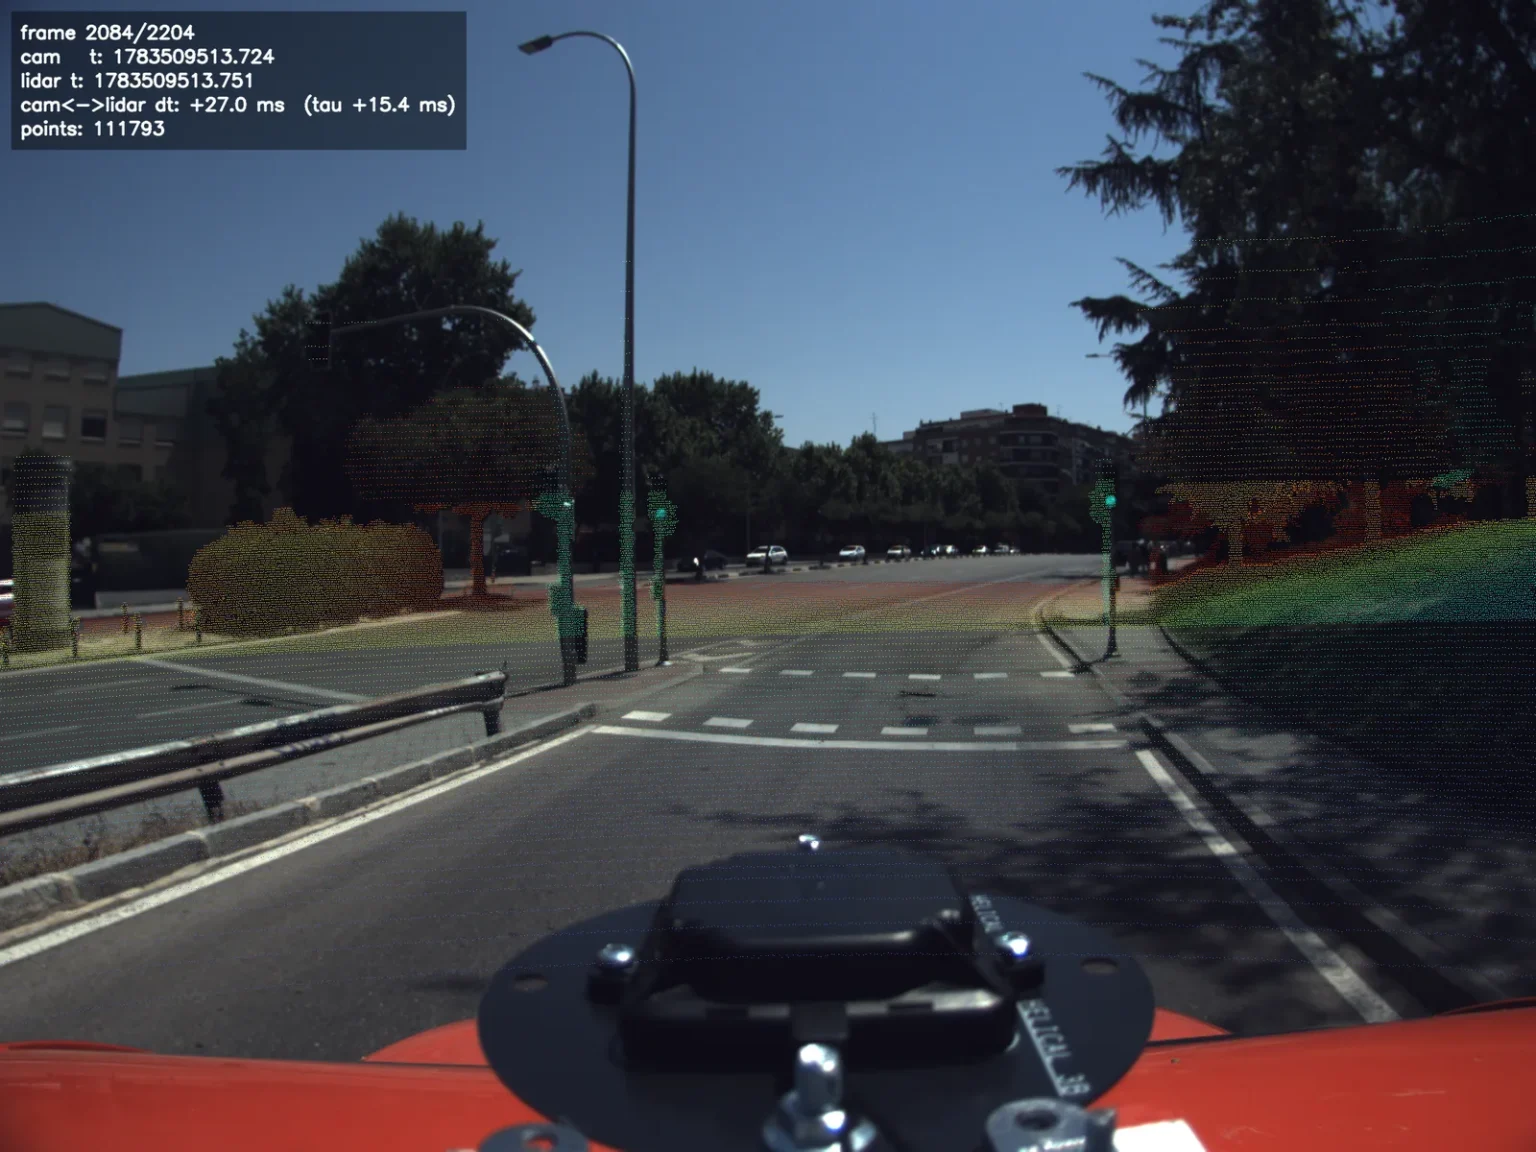
LiDAR projected onto the camera image.
04
Localisation
On georeferenced LiDAR and HD maps.
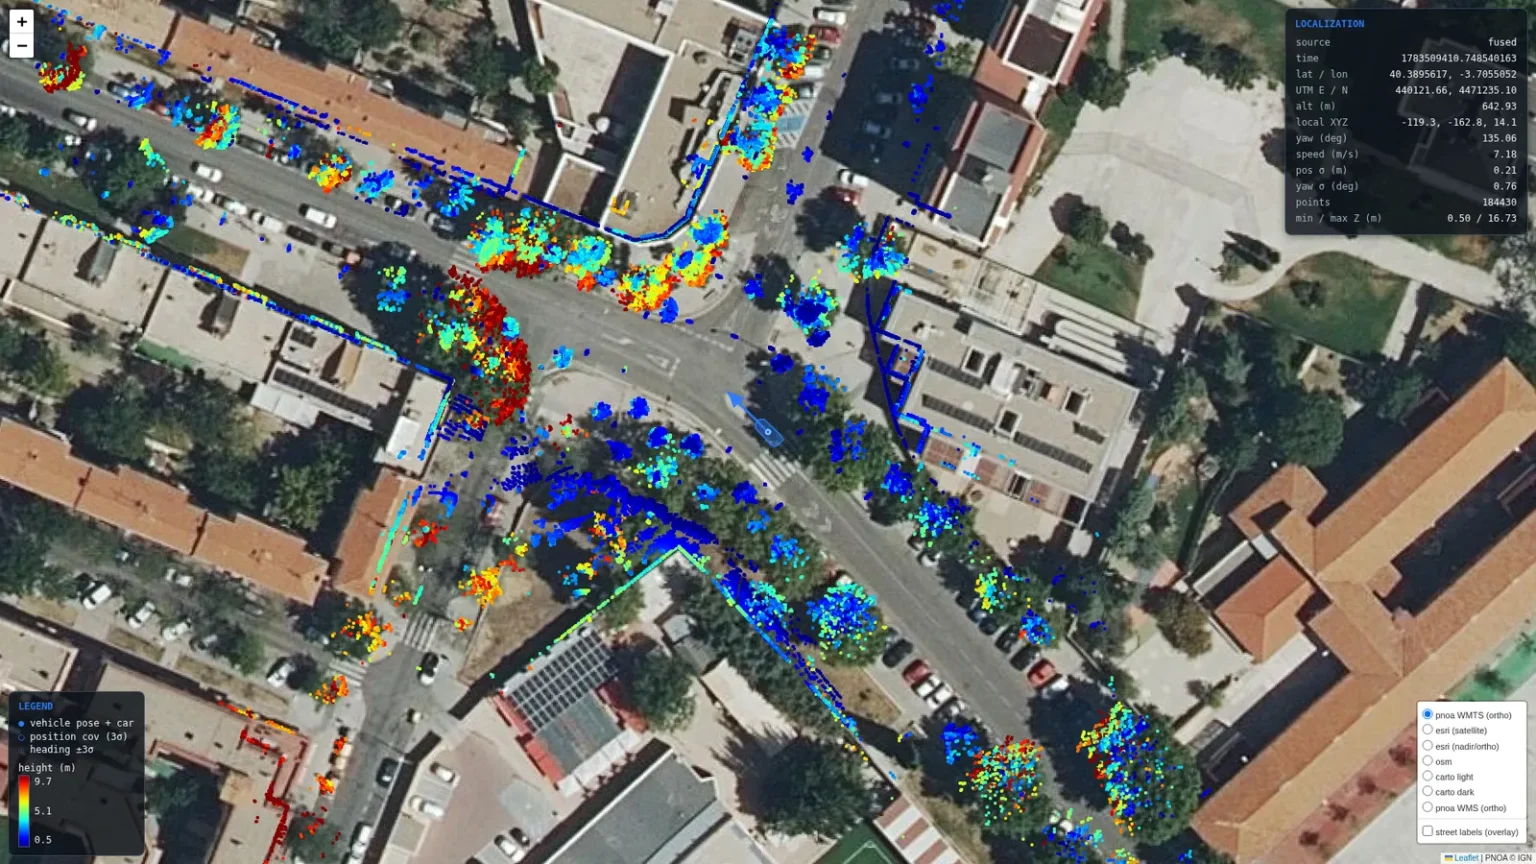
Localisation on georeferenced LiDAR.
05
Navigation and safety
Navigation architecture with a supervisor and safety layers.
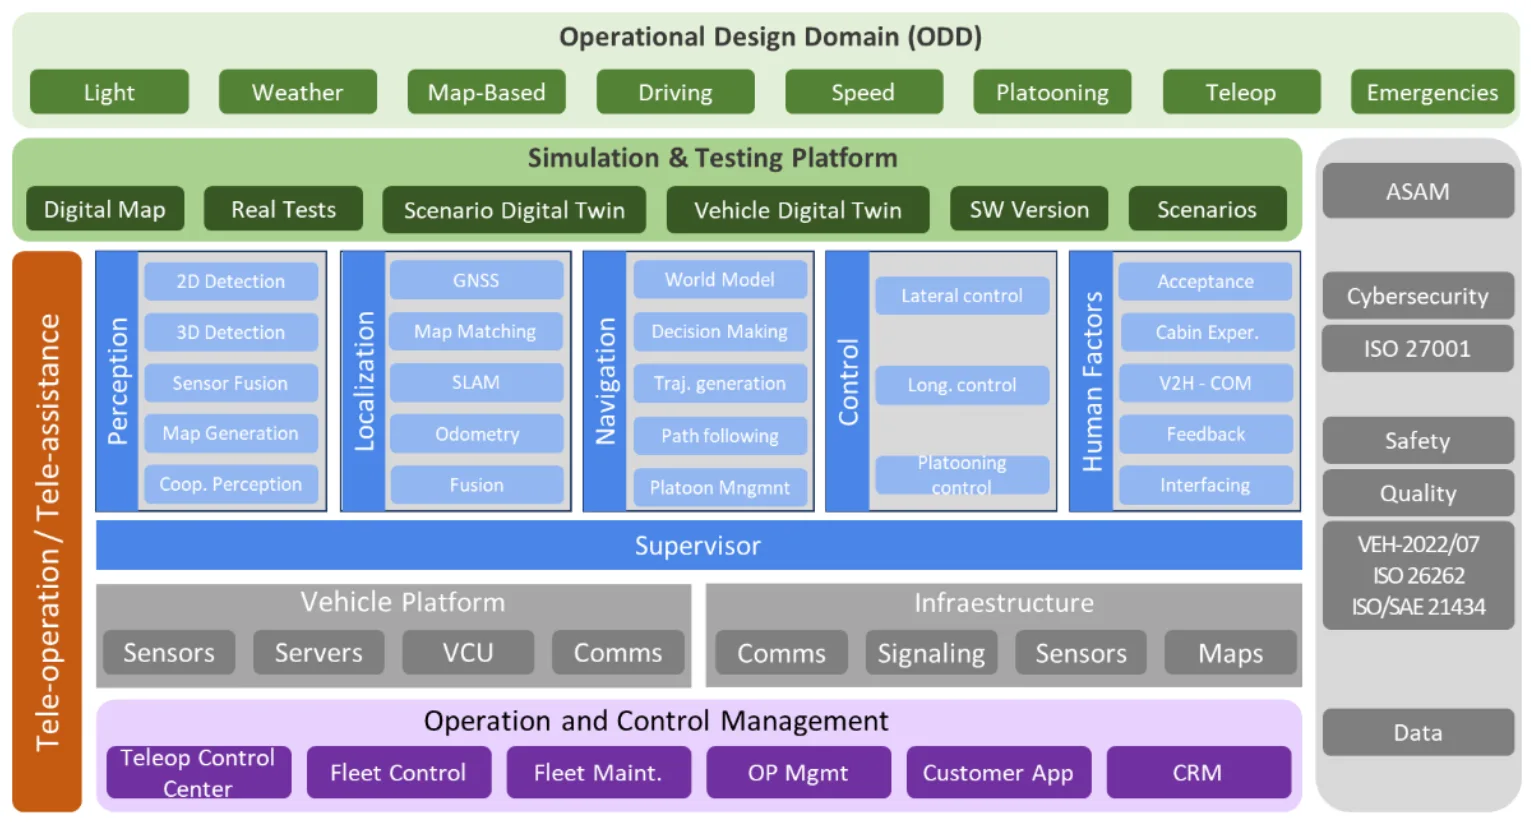
The driving architecture, layer by layer.
Equipment
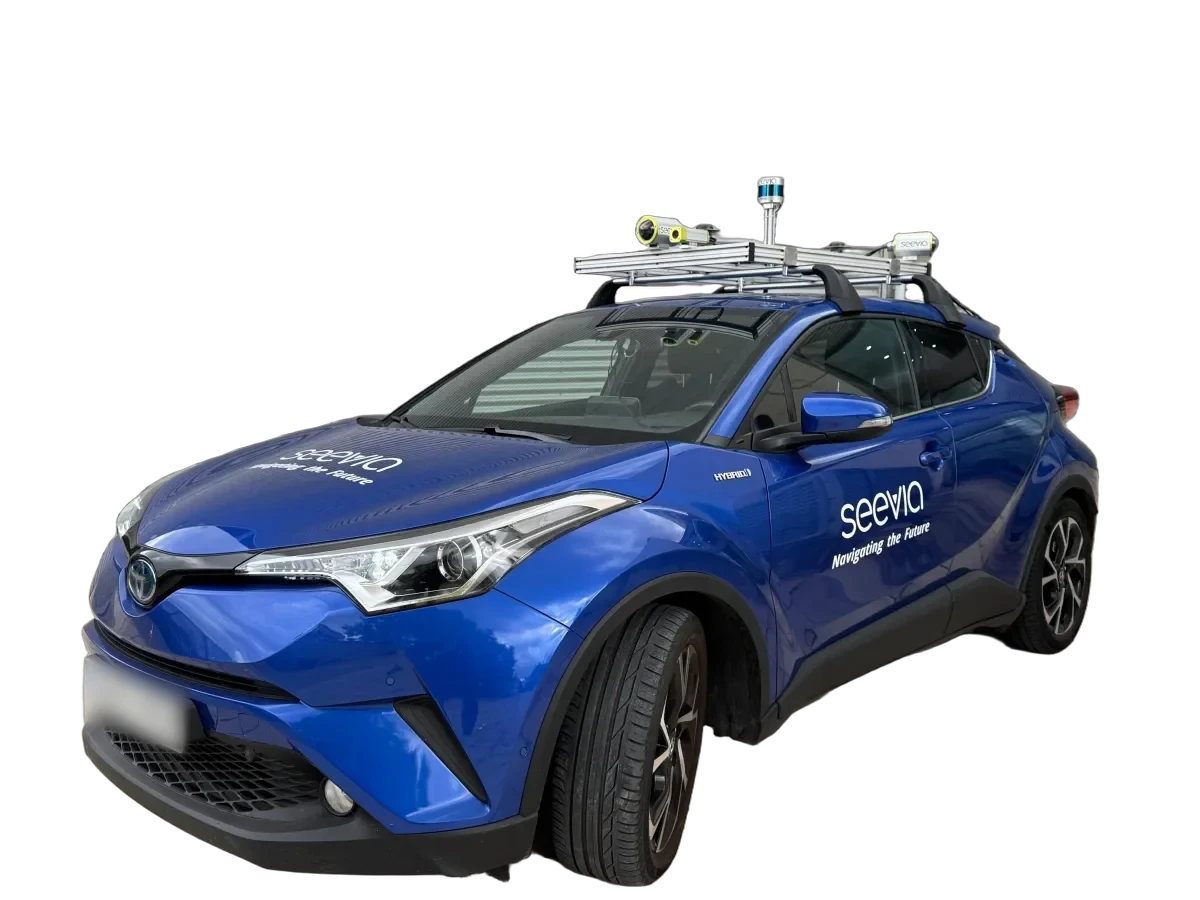
In each project we choose and mount the equipment the case needs. These are the elements we work with.
Sensors
Cameras, LiDAR, GNSS and IMU chosen, mounted and calibrated for each vehicle.
Computing
On-board computer and a safety ECU that supervises the system.
Vehicle
Connection to the vehicle bus and its drive-by-wire control.
Projects where it is used
A major European car manufacturer (OEM) · Obelix project
Software and safety for an industrial vehicle
We developed several autonomous driving modules for the vehicle: from automatic map generation from sensor recordings and the design of obstacle tracking systems to the programming of ASIL-B safety ECUs.
See the project →
An autonomous mobility company
Sensing, perception and localisation for an autonomous shuttle
We gave the autonomous shuttle a complete, robust perception and safety layer. We integrated three front cameras in a fan layout, four solid-state LiDARs and GNSS with IMU, together with our 3D perception and localisation software based on sensor fusion.
See the project →
GENIUS · R&D project
Perception in the 5G/6G network for an autonomous shuttle at the Port of Barcelona
We lead this use case: the perception of the shuttle that picks up drivers at the vehicle terminal runs on a 5G/6G network server located next to the antennas (edge), with on-board perception as backup if the network degrades.
See the project →
Questions
Can you provide just one part?
Yes: perception, localisation, validation or the whole, integrated with your architecture.
Which environments does it apply to?
Industrial and logistics sites, and urban environments in testing.
How is safety handled?
A safety ECU supervises the driving system, and each project follows the regulations that apply to it.
Let's talk
Tell us your case and we will look at it with your data.
Next
Seevia ADAS